
Young Researcher Paper Award 2025
🥇Winners
🥇Winners
Print: ISSN 0914-4935
Online: ISSN 2435-0869
Sensors and Materials
is an international peer-reviewed open access journal to provide a forum for researchers working in multidisciplinary fields of sensing technology.
Online: ISSN 2435-0869
Sensors and Materials
is an international peer-reviewed open access journal to provide a forum for researchers working in multidisciplinary fields of sensing technology.
Tweets by Journal_SandM
Sensors and Materials
is covered by Science Citation Index Expanded (Clarivate Analytics), Scopus (Elsevier), and other databases.
Instructions to authors
English 日本語
Instructions for manuscript preparation
English 日本語
Template
English
Publisher
MYU K.K.
Sensors and Materials
1-23-3-303 Sendagi,
Bunkyo-ku, Tokyo 113-0022, Japan
Tel: 81-3-3827-8549
Fax: 81-3-3827-8547
MYU Research, a scientific publisher, seeks a native English-speaking proofreader with a scientific background. B.Sc. or higher degree is desirable. In-office position; work hours negotiable. Call 03-3827-8549 for further information.
MYU Research
(proofreading and recording)
MYU K.K.
(translation service)
The Art of Writing Scientific Papers
(How to write scientific papers)
(Japanese Only)
is covered by Science Citation Index Expanded (Clarivate Analytics), Scopus (Elsevier), and other databases.
Instructions to authors
English 日本語
Instructions for manuscript preparation
English 日本語
Template
English
Publisher
MYU K.K.
Sensors and Materials
1-23-3-303 Sendagi,
Bunkyo-ku, Tokyo 113-0022, Japan
Tel: 81-3-3827-8549
Fax: 81-3-3827-8547
MYU Research, a scientific publisher, seeks a native English-speaking proofreader with a scientific background. B.Sc. or higher degree is desirable. In-office position; work hours negotiable. Call 03-3827-8549 for further information.
MYU Research
(proofreading and recording)
MYU K.K.
(translation service)
The Art of Writing Scientific Papers
(How to write scientific papers)
(Japanese Only)
Sensors and Materials, Volume 38, Number 11(1) (2026)
Copyright(C) MYU K.K.
Copyright(C) MYU K.K.
|
pp. 6401-6414
S&M4687 Research Paper https://doi.org/10.18494/SAM6528 Published: November 5, 2026 Development of Bendable Ultrasonic Scalpel with Grasping Mechanism Using Superelastic Alloy Active Blade [PDF] Daisuke Haraguchi and Ryoga Ono (Received July 14, 2026; Accepted August 25, 2026) Keywords: ultrasonic scalpel, flexible joint, superelastic alloy, grasping mechanism, robotic surgical instrument
In this study, we developed a multi-degree-of-freedom (multi-DOF) ultrasonic scalpel equipped with a superelastic alloy (NiTi) active blade that enables both tip bending and grasping motions. The active blade features a strip-shaped localized flexible section to facilitate compact bending, while a multistage hinge-based wire-driven mechanism achieves a bending range of ±60°. A blade-straddling single-moving-jaw grasping mechanism was also incorporated to provide grasping capability within the limited 8 mm outer diameter without interfering with the centrally routed active blade. The ultrasonic transducer can be easily detached from the active blade and replaced. A prototype device was fabricated on the basis of an active-blade design obtained by estimating the blade’s ultrasonic resonance using the finite element method, and its fundamental performance was evaluated through excitation experiments and noncontact 3D vibration measurements. In the straight, unloaded posture, the active blade exhibited a resonant frequency of 57.5 kHz and a transducer current of 528 mA at a driving voltage of 25 V. Stable ultrasonic resonance was maintained even in the bent state; however, vibration amplitude attenuation and durability issues were identified as major challenges. In cauterization experiments using an edible porcine meat sample, the grasping mechanism enabled effective wide-area cauterization in the straight posture, whereas sufficient cauterization was not achieved when the tip was bent.
Corresponding author: Daisuke Haraguchi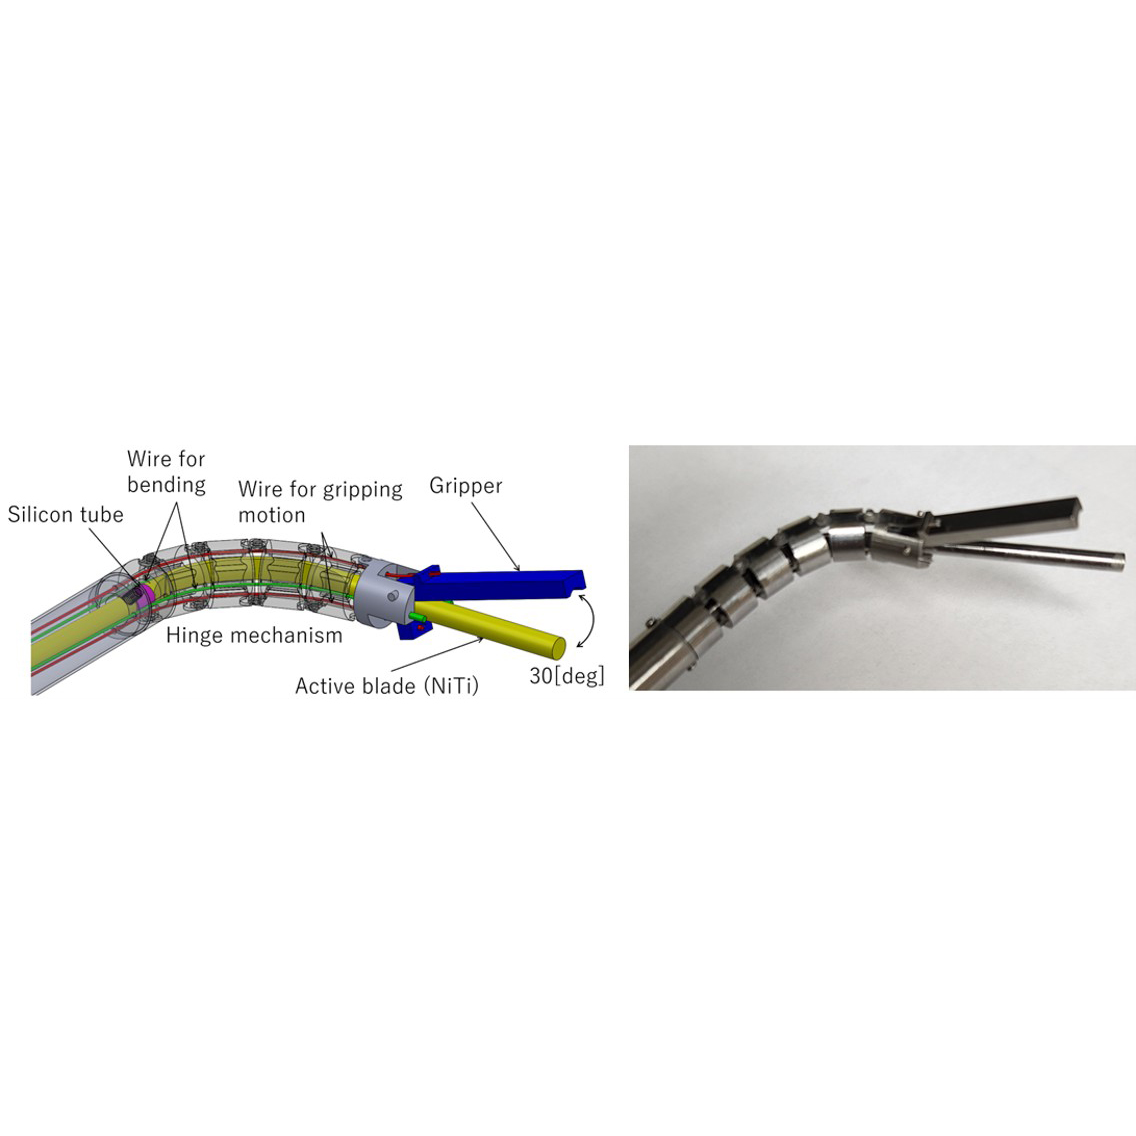  This work is licensed under a Creative Commons Attribution 4.0 International License. Cite this article Daisuke Haraguchi and Ryoga Ono, Development of Bendable Ultrasonic Scalpel with Grasping Mechanism Using Superelastic Alloy Active Blade, Sens. Mater., Vol. 38, No. 11, 2026, p. 6401-6414. |
Forthcoming Regular Issues
Forthcoming Special Issues
Special Issue on Signal Collection, Processing, and System Integration in Automation Applications 2026
Guest editor, Hsiung-Cheng Lin (National Chin-Yi University of Technology), Ming-Te Chen (National Chin-Yi University of Technology), and Chin-Yi Cheng (National Yunlin University of Science and Technology)
Call for paper
Special Issue on Converging Smart Materials, Artificial Intelligence, and Quantum Technologies for Intelligent Sensing and Future Electronics
Guest editor, Prof. Wipoo Sriseubsai (King Mongkut’s Institute of Technology Ladkrabang)
Call for paper
Special Issue on Emerging Trends in Advanced Sensor Applications
Guest editor, Shih-Chen Shi (National Cheng Kung University) and Tao-Hsing Chen (National Kaohsiung University of Science and Technology)
Call for paper
Special Issue on Sensing Beyond Transduction: Materials, Devices, and Signal Processing for Intelligent Sensory Systems
Guest editor, Masayuki Sohgawa (Niigata University)
Call for paper
Special Issue on Advanced Materials and Technologies for Sensor and Artificial- Intelligence-of-Things Applications (Selected Papers from ICASI 2026)
Guest editor, Sheng-Joue Young (National Yunlin University of Science and Technology)
Conference website
Call for paper
Special Issue on Biosensing Devices
Guest editor, Kiyotaka Sasagawa (Nara Institute of Science and Technology)
Call for paper
-
For more information of Special Issues (click here)
-
Special Issue on Ceramic- and Glass-based Gas Sensing: Materials, Mechanisms, and Applications
- Accepted papers (click here)
- GRT-Net: Offline Light Detection and Ranging-supervised Stereo Ranging Residual Correction for Payload-constrained Outdoor Unmanned Platforms
Kun Chang, Liang Wang, Zhenyao Liu, Jidong Guo, Xintong Yin, and Shengkai Jiao
- GRT-Net: Offline Light Detection and Ranging-supervised Stereo Ranging Residual Correction for Payload-constrained Outdoor Unmanned Platforms
- Accepted papers (click here)
- Negative Temperature Coefficient Thermistor with Multilayer Thin-film Structure AlN/VOx/AlN on Si(100) Substrate
Chen-Hung Yen, Ing-Jiunn Su, and Hui-Huang Hsieh
- Negative Temperature Coefficient Thermistor with Multilayer Thin-film Structure AlN/VOx/AlN on Si(100) Substrate
Guest editor, Yoshiteru Itagaki (Ehime University)
Call for paper
Topics on Novel Sensors, Materials, and Related Technologies on Artificial Intelligence of Things Applications
Guest editor, Teen-Hang Meen (National Formosa University), Wenbing Zhao (Cleveland State University), and Cheng-Fu Yang (National University of Kaohsiung)
Call for paper
Special Issue on Low-altitude Economy: Technologies, Infrastructure, and Applications
Guest editor, He Huang and Junxing Yang (Beijing University of Civil Engineering and Architecture)
Call for paper
Special Issue on Materials, Devices, Circuits, and Analytical Methods for Various Sensors (Selected Papers from ICSEVEN 2026)
Guest editor, Chien-Jung Huang (National University of Kaohsiung), Mu-Chun Wang (Minghsin University of Science and Technology), Shih-Hung Lin (Chung Shan Medical University), Ja-Hao Chen (Feng Chia University)
Conference website
Call for paper
Special Issue on Sensing and Data Analysis Technologies for Living Environment, Health Care, Production Management, and Engineering/Science Education Applications (2026)
Guest editor, Chien-Jung Huang (National University of Kaohsiung), Rey-Chue Hwang (I-Shou University), Ja-Hao Chen (Feng Chia University), Ba-Son Nguyen (University of Economics Ho Chi Minh City)
Call for paper
Special Issue on Multisource Sensors for Resource and Environmental Monitoring: Theories, Models, Methods, and Application
Guest editor, Chao Chen (Suzhou University of Science and Technology)
Call for paper
Special Issue on Spatial Intelligence, Digital Twins, and AI-driven Smart Systems for Next-Generation Built Environment
Guest editor, Jaekang Lee (Dong-A University), Myeong Hun Jeong (Chosun University), and Dong Ha Lee (Kangwon National University),
Call for paper
Special Issue on Intelligent Sensing and AI-driven Optimization for Sustainable Smart Manufacturing
Guest editor, Cheng-Chi Wang (National Sun Yat-sen University)
Call for paper
- Accepted papers (click here)
Copyright(C) MYU K.K. All Rights Reserved.